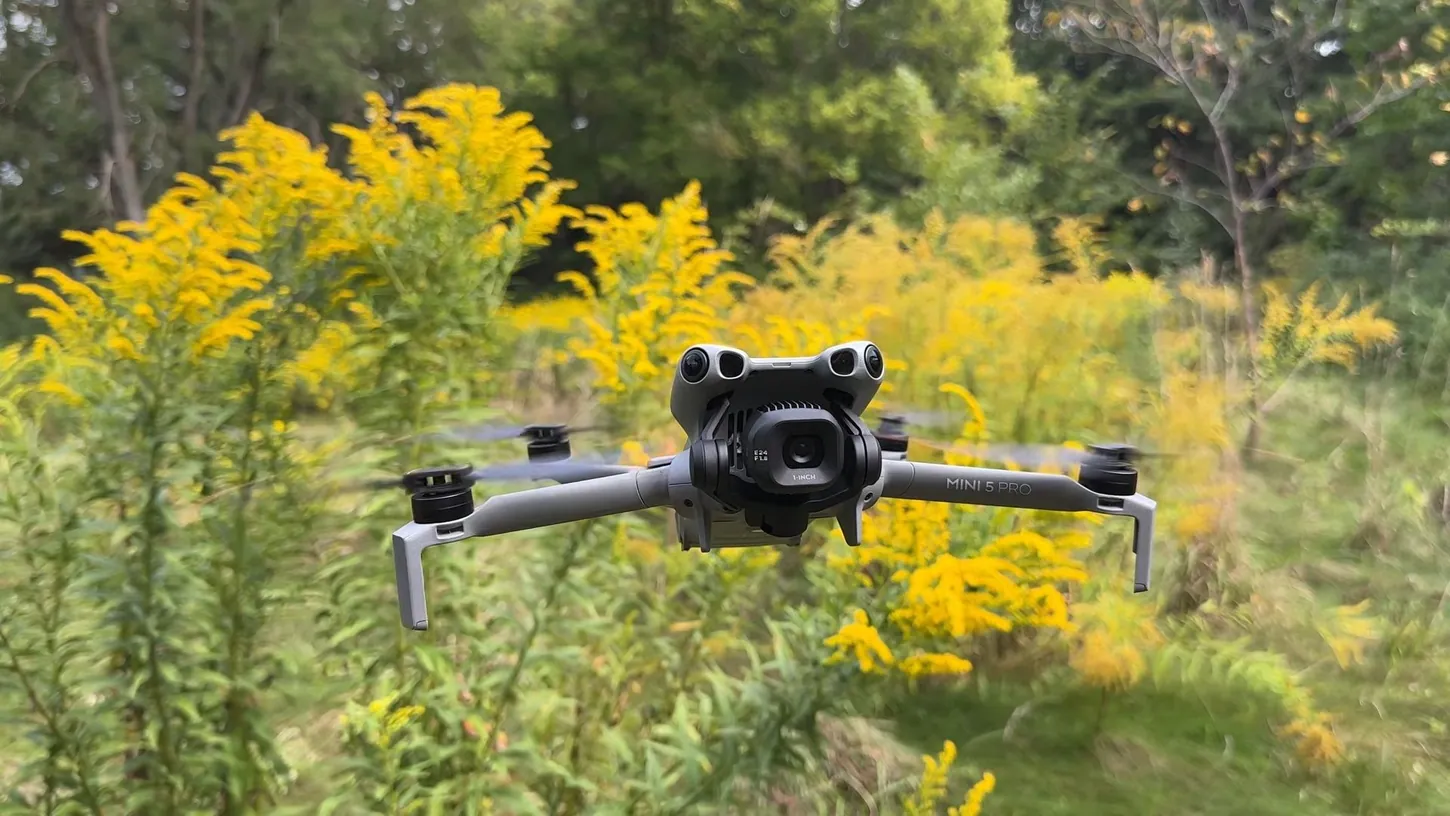
Over the past decade, MIT researchers have developed aerial microrobots with bumblebee-like speed, agility and durability for tasks like precision agriculture or search and rescue. But these featherweight microrobots couldn’t carry the electronics needed for navigation, forcing them to remain connected to a motion-capture system in the lab. Read More
Newsletter
Get the Physical AI brief
The day’s most important robotics and embodied-AI stories, in your inbox.